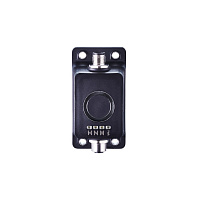
Positioners are used to move valve flaps and ball valves precisely to a desired position based on a signal from the control level.
The solution developed by ifm uses the proven MVQ sensor platform and extends it with a control algorithm. This analyzes the positioning signal (target value) from the control system, compares it with the current position of the valve flap or ball valve (actual value) and controls a solenoid valve according to this information.
The solenoid valve regulates the supply and exhaust air of a pneumatic rotary actuator, which finally moves the valve flap to the desired position. Once positioning is complete, the MVQ sends a signal to the controller to confirm that the process has been completed and feedback is provided via IO-Link about the exact position of the valve flap or ball valve.
The position of the process valve is monitored throughout the entire use of the positioner and readjusted in the event of any deviations.