| Technical Data |
|
| Size |
16 |
| Total stroke |
16 |
| Stroke per gripper jaws |
8 |
| Max. angular gripper jaw backlash ax, ay |
0 |
| Max. gripper jaw backlash Sz |
0 |
| Repetition accuracy, gripper |
0.06 |
| Number of gripper jaws |
2 |
| Drive system |
Pneumatic |
| Mounting position |
optional |
| Mode of operation |
Double-acting |
| Cushioning |
On one sideNot adjustable |
| Gripper function |
Parallel |
| Gripper force back-up |
During closing |
| Design |
Force pilot operated motion sequence |
| Guide |
Ball guide |
| Position detection |
With integrated displacement encoder |
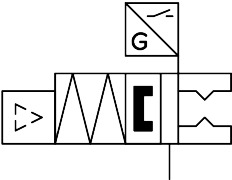
| Symbol |
00997553 |
| Switching status indication |
Blue LED, switching status via signal input |
| Operating pressure |
36.25101.5 |
| Operating pressure HRC |
36.2572.5 |
| Max. operating frequency of gripper |
1 |
| Min. opening time at 0.6 MPa (6 bar, 87 psi) |
180 |
| Min. closing time at 0.6 MPa (6 bar, 87 psi) |
90 |
| Max. mass per external gripper finger |
100 |
| Max. current consumption |
100 |
| Nominal operating voltage DC |
24 |
| Switching output |
PNP |
| Switching input |
NPN |
| Permissible voltage fluctuations |
+/- 10 % |
| Approval |
RCM trademark |
| CE mark (see declaration of conformity) |
To EU EMC DirectiveIn accordance with EU RoHS Directive |
| UKCA marking (see declaration of conformity) |
To UK instructions for EMCTo UK RoHS instructions |
| Certificate issuing authority |
TÜV Süd M70132770525.01 |
| Operating medium |
Compressed air to ISO 8573-1:2010 [7:4:4] |
| Note on operating and pilot medium |
Lubricated operation possible (in which case lubricated operation will always be required) |
| Shock resistance |
Shock test with severity level 2 to FN 942017-5 and EN 60068-2-27 |
| Corrosion resistance class CRC |
1 - Low corrosion stress |
| LABS (PWIS) conformity |
VDMA24364 zone III |
| Vibration resistance |
Transport application test with severity level 2 to FN 942017-4 and EN 60068-2-6 |
| Relative air humidity |
0 - 90%Non-condensing |
| Sound pressure level |
75 |
| Degree of protection |
IP40 |
| Ambient temperature |
-550 |
| Total gripping force, closing, 0.6MPa (6bar, 87 psi) |
278302 |
| Gripper force per gripper jaw, closing, 0.6 MPa (6 bar, 87 psi) |
139151 |
| Total gripping force HRC, closing |
232256 |
| Gripping force per gripper jaw HRC, closing |
116128 |
| Note on gripping force |
Dependent on the strokeWith integrated compression spring |
| Theoretical spring force per gripper jaw, closing |
23.334.9 |
| Mass moment of inertia |
0.6 |
| Max. force on gripper jaw Fz static |
176 |
| Max. moment Mx |
2.8 |
| Max. moment My |
1.4 |
| Max. moment Mz |
1.4 |
| Bending radius, fixed cable |
26 |
| Bending radius, moving cable |
52 |
| Maintenance interval |
Life-time lubrication |
| Product weight |
680 |
| Recommended workpiece weight for MRK |
1 |
| Electrical connection 1, function |
Field device side |
| Electrical connection 1, connection type |
Cable with socket |
| Electrical connection 1, cable outlet |
Angled |
| Electrical connection 1, design |
Round |
| Electrical connection 1, connector system |
M8x1, A-coded, to EN 61076-2-104 |
| Electrical connection 1, number of connections/cores |
8 |
| Electrical connection 1, used connections/cores |
6 |
| Electrical connection 1, connection pattern |
00997559 |
| Electrical connection 1, tightening torque |
0.2 |
| Type of mounting |
Via mounting kitTo ISO 9409 |
| Pneumatic connection |
For push-in connector O.D. 4 mm |
| Note on materials |
RoHS-compliant |
| Material cover |
PA-reinforced |
| Material spring |
High-alloy stainless steel |
| Material housing |
Anodised wrought aluminium alloy |
| Material gripper jaws |
High-alloy steel |
| Material piston |
Wrought aluminium alloy, anodised |
| Material piston seal |
TPE-U(PU) |
| Material o-ring |
HNBRNBR |
| Material screws |
Galvanised steelHigh-alloy steel |
| Gear wheel material |
High-alloy steel |
| Gripper finger material |
Wrought aluminium alloy, anodised |