| Technical Data |
|
| Size |
16 |
| Stroke per gripper jaws |
10 |
| Max. replacement accuracy |
0.2 |
| Max. angular gripper jaw backlash ax, ay |
0.4 |
| Max. gripper jaw backlash Sz |
0.05 |
| Rotationally symmetrical |
0.2 |
| Repetition accuracy, gripper |
0.03 |
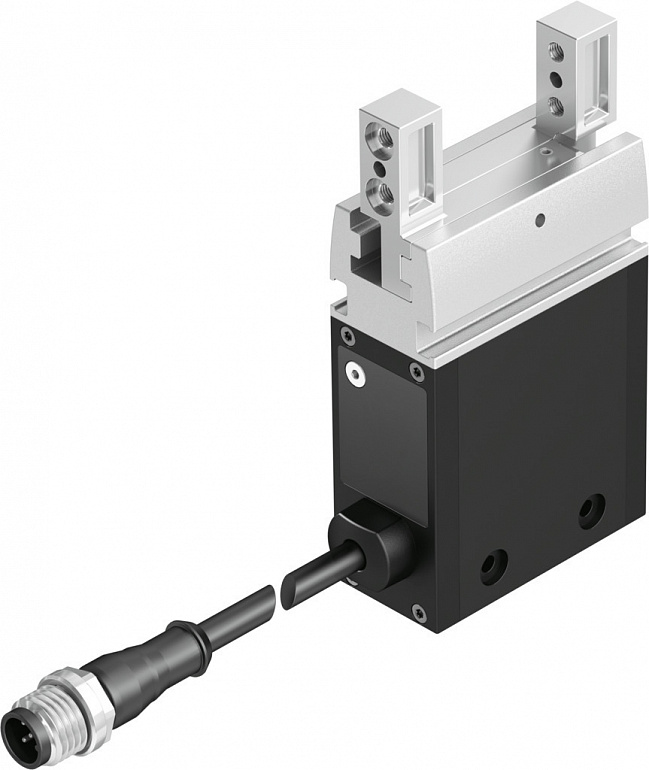
| Number of gripper jaws |
2 |
| Drive system |
Electrical |
| Mounting position |
optional |
| Gripper function |
Parallel |
| Design |
Worm gear unitT-shapeRack and pinionElectric gripper |
| Conforms to standard |
IEC 61010-1 |
| Guide |
Plain-bearing guide |
| Position detection |
With Hall sensorWith integrated displacement encoderVia IO-Link interface |
| Symbol |
00992258 |
| Type of motor |
DC servo motor |
| Ready status indication |
LED |
| Max. cycle frequency |
1.1 |
| Max. mass per external gripper finger |
100 |
| Max. current consumption |
1000 |
| Nominal operating voltage DC |
24 |
| Permissible voltage fluctuations |
+/- 10 % |
| Approval |
RCM trademark |
| KC mark |
KC-EMV |
| CE mark (see declaration of conformity) |
To EU EMC DirectiveIn accordance with EU RoHS Directive |
| UKCA marking (see declaration of conformity) |
To UK instructions for EMCTo UK RoHS instructions |
| Explosion protection certification outside the EU |
EPL Db (GB)EPL Gb (GB) |
| Explosion protection |
Zone 1 (UKEX)Zone 21 (UKEX) |
| Corrosion resistance class CRC |
1 - Low corrosion stress |
| LABS (PWIS) conformity |
VDMA24364-B2-L |
| Suitability for the production of Li-ion batteries |
Metals with more than 5% by mass of copper are excluded from use. Exceptions are printed circuit boards, cables, electrical plug connectors and coils |
| Sound pressure level |
70 |
| Degree of protection |
IP40 |
| Ambient temperature |
560 |
| Total gripping force |
154 |
| Mass moment of inertia |
0.78 |
| Max. force on gripper jaw Fz static |
200 |
| Max. torque at gripper Mx static |
7 |
| Max. torque at gripper My static |
4.4 |
| Max. torque at gripper Mz static |
7 |
| Lubrication interval for guide components |
2 |
| Product weight |
296 |
| Protocol |
IO-Link® |
| IO-Link, Protocol version |
Device V 1.1 |
| IO-Link, communication mode |
COM3 (230.4 kBaud) |
| IO-Link, SIO-Mode support |
No |
| IO-Link, Port class |
Device B |
| IO-Link, Number of ports |
Device 1 |
| IO-Link, Process data length OUT |
8 bytes |
| IO-Link, Process data content OUT |
16 bit (ControlWord)16 bit (GrippingPosition)8-bit (GrippingForce)8 bit (GrippingMode)8 bit (GrippingTolerance)8 bit (WorkpieceNo) |
| IO-Link, Process data length IN |
6 bytes |
| IO-Link, Process data content IN |
16-bit (ActualPosition)16 bit (ErrorNumber)16 bit (StatusWord) |
| IO-Link, Min. cycle time |
5 ms |
| IO-Link, Data storage required |
500 |
| IO-Link, Device ID |
0x000031 |
| Electrical connection |
5-pinCable with plugM12x1 |
| Type of mounting |
Either:Via female thread and centring sleeveVia through-hole and centring sleeve |
| Note on materials |
RoHS-compliant |
| Material housing |
Anodised wrought aluminium alloy |
| Material gripper jaws |
High-alloy stainless steel |