| Technical Data |
|
| Size |
20 |
| Inverting cap version |
Standard |
| Stroke |
66 |
| Min. ø to be gripped |
12 |
| Max. ø to be gripped |
38 |
| Drive system |
Pneumatic |
| Mounting position |
optional |
| Mode of operation |
Double-acting |
| Gripper function |
Adaptive |
| Design |
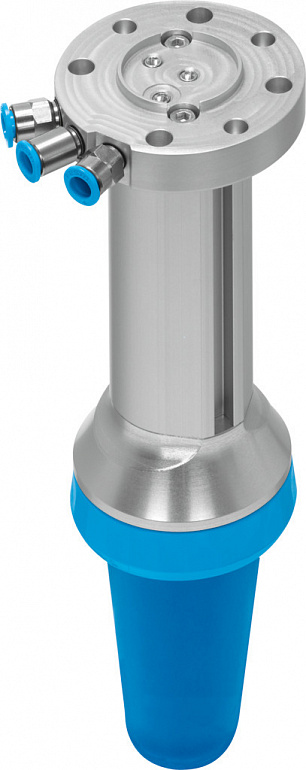
Inverting capForce pilot operated motion sequence |
| Guide |
Basic guide |
| Position detection |
Via proximity switch |
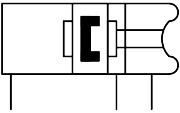
| Symbol |
00997278 |
| Pick-up tolerance |
±4 mm |
| Placement tolerance |
±2 mm |
| Operating pressure of ball valve drive unit |
18 |
| Operating pressure of cap |
0.070.1 |
| Burst pressure of cap |
0.3 |
| Recommended flow rate for pressure regulator |
10 |
| Max. operating frequency of gripper |
1 |
| Return-stroke time |
290 |
| Advance time |
270 |
| Max. speed without gripped object |
290 |
| Max. speed during gripping |
120 |
| Operating medium |
Compressed air to ISO 8573-1:2010 [7:4:4] |
| Note on operating and pilot medium |
Lubricated operation not possible |
| Corrosion resistance class CRC |
2 - Moderate corrosion stress |
| LABS (PWIS) conformity |
VDMA24364 zone III |
| Suitable for use with food |
See supplementary material information |
| Ambient temperature |
060 |
| Mass moment of inertia |
1.29 |
| Theoretical force at 0.6 MPa (6 bar, 87 psi), advance stroke |
158 |
| Theoretical force at 0.6 MPa (6 bar, 87 psi), return stroke |
189 |
| Dynamic lateral force with max. projection |
2.3 |
| Contact force on the gripping object |
20 |
| Static holding force parallel to the gripper axis |
26 |
| Static holding force perpendicular to the gripper axis |
45 |
| Impact energy in end positions |
0.1 |
| Guide value for effective load |
1 |
| Product weight |
475 |
| Moving mass |
60 |
| Note on the moving mass |
Without inverting cap |
| Type of mounting |
To ISO 9409 |
| Pneumatic connection |
M5 |
| Note on materials |
RoHS-compliant |
| Material cap |
VMQ (silicone) |
| Material housing |
Anodised aluminium |
| Locking cover material |
PA |